Flagship · 5-axis
SubArm5 Lite
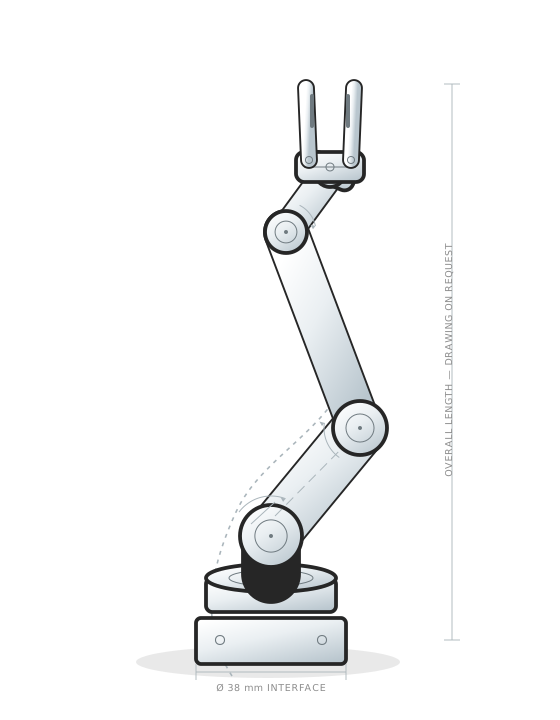
The world's smallest and lightest 5-axis subsea manipulator. Continuous rotation, all-electric actuation and a parallel jaw that fits a micro ROV.
Products
From three-axis inspection to dual-arm intervention, every SubArm shares the same sealed electric joints, the same Ø 38 mm tool interface and the same control stack.
Flagship · 5-axis
The world's smallest and lightest 5-axis subsea manipulator. Continuous rotation, all-electric actuation and a parallel jaw that fits a micro ROV.
Cost-efficient · 3-axis
Three powered axes for inspection-class work, at a price that lets you fit an arm to every vehicle in the fleet.
Dual-arm · 10 axes
Two 5-axis arms on one vehicle, a one-to-two interface and 10–60 V input. Hold, cut and recover with a single pilot.
Controller
The first gesture-tracking manipulator controller. Touch, joystick, Joy-Con, SpaceMouse and keyboard — over ROS 2 and an open protocol.
Engineering
No hydraulics. No oil. No diver in the loop. A sealed electric joint stack that survives pressure, salt and a long deployment.
All-electric
Sealed electric actuators remove the pump, the reservoir and the leak risk. Ten to thirty-two volts is the whole installation.
Continuous rotation
Base yaw and wrist roll rotate continuously, so a tether never winds up mid-task and a tool can be indexed through a full revolution.
Open by default
CAN and TTL at the wire, ROS 2 at the top. Spatial inverse kinematics, open protocol, Windows and Linux host software.
Value
A conventional work-class arm arrives with a hydraulic power unit, a reservoir, valves and a technician. SubArm arrives with a cable. Integrators typically land the installed cost of a SubArm system up to 80 % below a comparable hydraulic manipulator.
Applications
Clear a fouled prop, turn a latch, place a sensor — dexterous work from the control room.
Grab, cut and basket evidence or debris in a single dive, with a wrist camera on the tool.
Net repair, mort recovery and mooring checks with a small ROV that a two-person crew can launch.
A ROS 2 arm small enough for a lab tank, a student vehicle and a repeatable experiment.
Tooling
Mounting geometry, thrust budgets, comms — we answer within one working day.
Start a conversation ›SubArm
Even fish wish for hands.
Tell us what your vehicle needs to hold, cut or recover. We will send the mounting drawing, the control notes and a quote.


