 Render
Cost-efficient · 3-axis
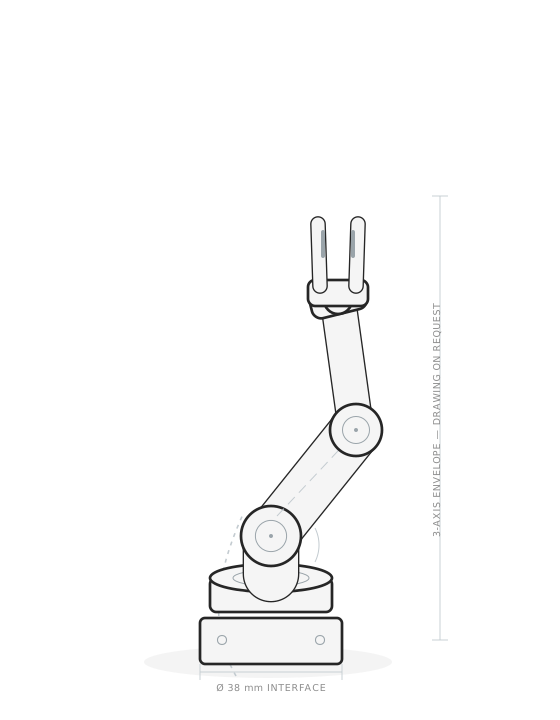
SubArm3 Lite
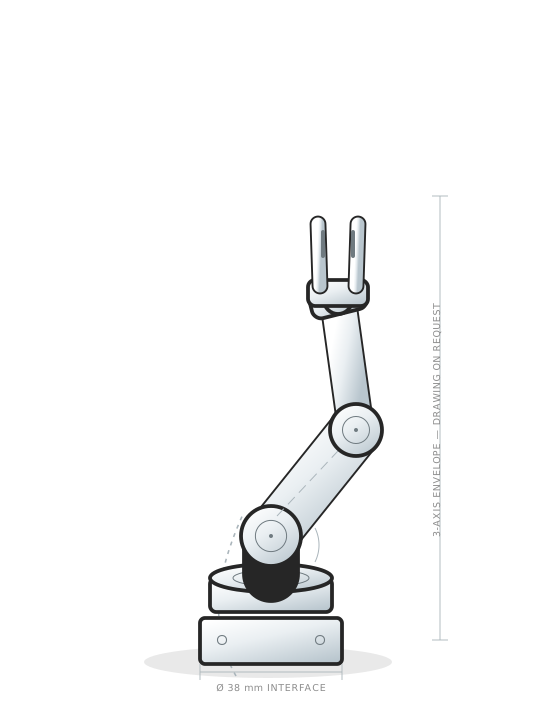
A low-cost three-axis subsea manipulator for inspection and light intervention.
- Three powered axes plus jaw
- Continuous base rotation
- Shares the SubArm control stack
- Axes
- 3 + gripper
- Mass
- On request
- Interface
- Ø 38 mm
- Input
- 10–32 V DC
- Comms
- CAN / TTL
- Control
- SubArm Ctrl · ROS 2
Mass, reach and mounting geometry depend on the jaw and cable set. Request the mounting drawing for the exact envelope.
Fleet economics
A manipulator you can afford to fit everywhere.
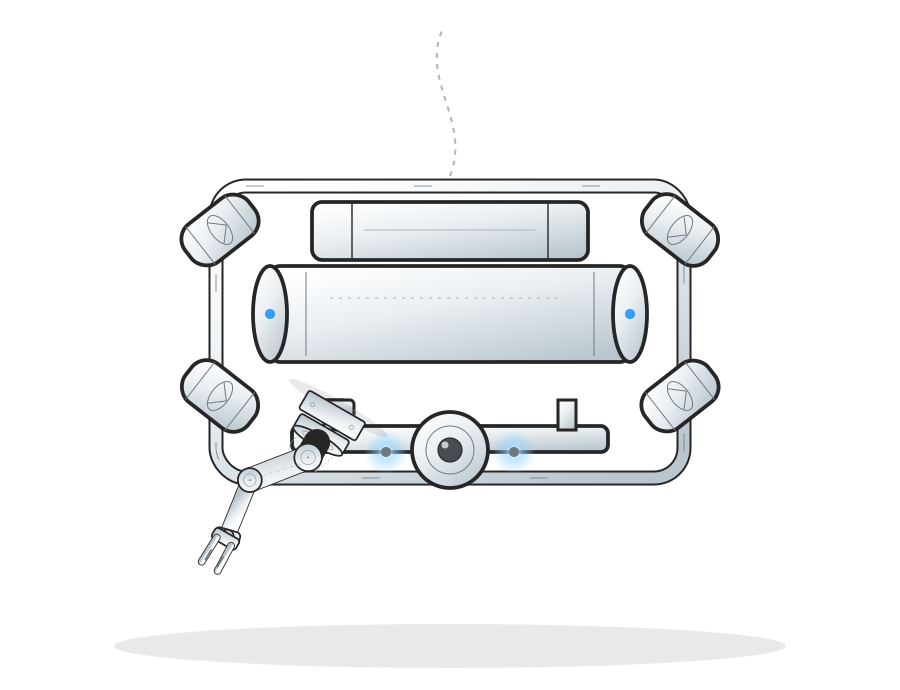
Not every mission needs five axes. SubArm3 Lite keeps the sealed electric joints, the continuous base rotation and the Ø 38 mm tool interface, and removes the wrist — so an inspection ROV can carry a working arm without a working-arm budget.
Capability
Three axes, real work.
Base yaw, shoulder and elbow cover the reach-and-place moves that most inspection tasks need: clearing debris, placing a sensor, recovering a sample. The interchangeable jaw does the rest.
- Continuous base yaw
- Shoulder and elbow working arc
- Same jaws as SubArm5 Lite
Cost
Priced per vehicle, not per project.
Without a wrist and with a simpler harness, SubArm3 Lite lands at a fraction of the cost of a hydraulic arm. Fleets can standardise on one arm instead of budgeting for a single shared manipulator.
- No hydraulic power unit
- One cable for power and comms
- Same spares across the fleet
Control
Same stack, same crew.
SubArm3 Lite speaks the same protocol and uses the same SubArm Ctrl hand controller as the five-axis arm. A pilot who can fly one can fly the other.
- SubArm Ctrl compatible
- ROS 2 and Windows / Linux hosts
- Open register map
Specifications
SubArm3 Lite, in full.
| Mechanical | |
|---|---|
| Axes | 3 — base yaw, shoulder, elbow |
| End effector | Parallel jaw, interchangeable via Ø 38 mm interface |
| Mass | Configuration dependent — request the drawing |
| Mounting | Quick-release flange |
| Rotation | Continuous base yaw |
| Electrical | |
| Input voltage | 10–32 V DC |
| Protocol | CAN 2.0B or TTL UART, selectable |
| Connector | Single sealed connector |
| Actuation | All-electric, sealed joints |
| Control | |
| Controller | SubArm Ctrl or third-party host |
| Host software | Windows / Linux |
| Interface | ROS 2 package, open protocol |
Specifications are subject to change. The mounting drawing issued with every quote is the controlling document.
Tooling
One interface, six hands.


Questions
Before you integrate.
What can a three-axis arm actually do?
Reach, push, place and recover. With a cutter or basket on the wrist it covers most inspection-class intervention tasks; for wrist articulation and tool indexing, step up to SubArm5 Lite.
Is it the same control stack as the five-axis arm?
Yes. SubArm3 Lite uses the same SubArm Ctrl hand controller, the same ROS 2 package and the same CAN register layout, with the wrist entries reported as unavailable.
Can I upgrade later?
The tool interface and mounting flange are shared across the family, so an ROV wired for SubArm3 Lite can move to SubArm5 Lite without a new harness.
Why is the mass listed as “on request”?
Mass depends on the jaw, the cable length and the mount. The mounting drawing issued with your quote states the exact figure for your configuration.
Next step
Arm the whole fleet.
Tell us how many vehicles and what they need to do. We will quote a fleet configuration with shared spares.