 Render
Flagship · 5-axis
SubArm5 Lite
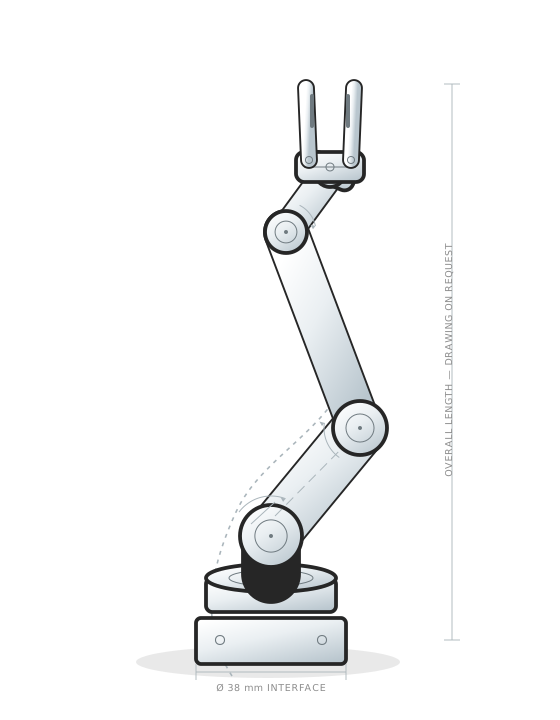
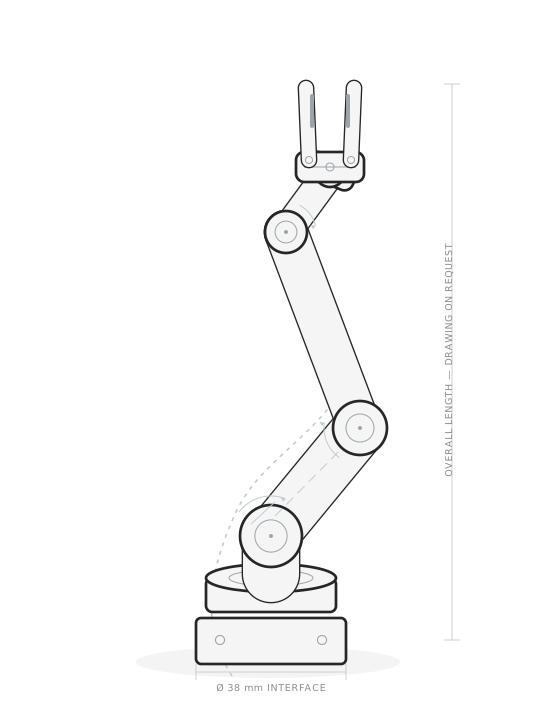
The world’s smallest, lightest 5-axis subsea manipulator. Dexterous intervention on a micro ROV.
- 800 g including the parallel jaw
- Continuous rotation on base and wrist
- ROS 2 package and open CAN protocol included
- Axes
- 5 + gripper
- Mass
- 800 g
- Envelope
- Ø 38 mm
- Input
- 10–32 V DC
- Comms
- CAN / TTL
- Control
- SubArm Ctrl · ROS 2
Quote covers the arm, jaw, cable set and mounting flange. Tell us your vehicle voltage, comms and tool and we will specify the kit.
Why it exists
Five axes that fit where an arm used to be impossible.
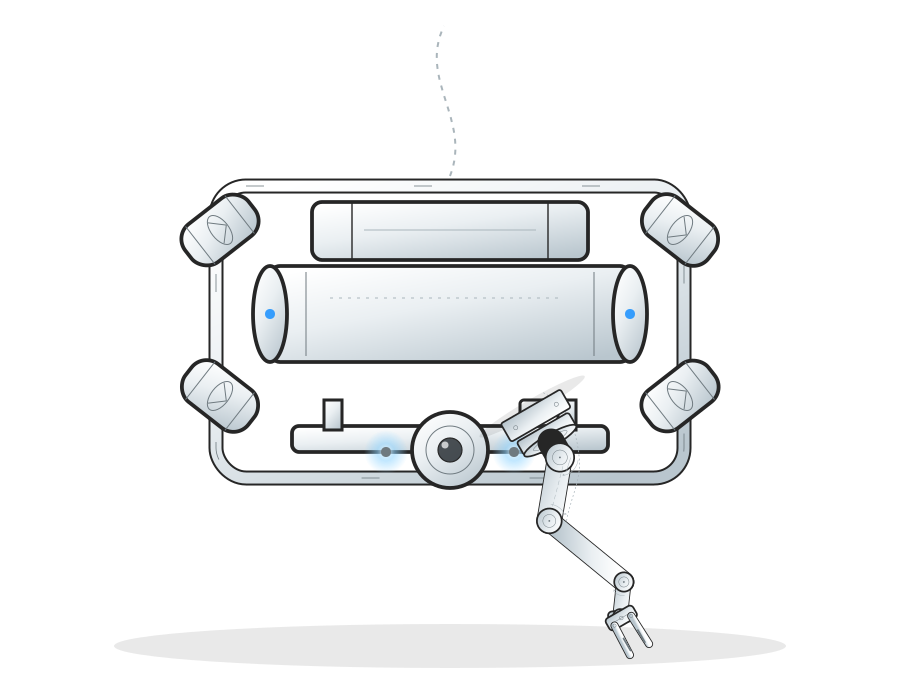
Micro ROVs have the cameras and the thrust, but rarely the payload, power or deck space for a hydraulic manipulator. SubArm5 Lite is built around that constraint: a complete five-axis arm in 800 g and Ø 38 mm, driven from the vehicle bus.
Form factor
Small enough to disappear.
At 800 g and Ø 38 mm, SubArm5 Lite mounts on the vehicles that already do the work — inspection-class and micro ROVs — without a counterweight, a power unit or a new skid design.
- Bolts to a flat skid with a four-bolt flange
- No hydraulic hoses or oil volume to route
- Leaves payload and thrust budget for the mission
Motion
Continuous rotation, end to end.
Base yaw and wrist roll turn without end stops. The tether never winds up mid-task, and a tool can be indexed through a full revolution without backing out.
- Base yaw: continuous
- Wrist roll: continuous
- Shoulder, elbow and wrist pitch: full working arc
Integration
One cable. Two protocols.
Power and communication share a single sealed connector: 10–32 V in, CAN or TTL out. Choose the protocol at commissioning rather than at the factory, and run the arm from the ROV multiplexer you already have.
- 10–32 V DC input, tolerant of 12 V and 24 V buses
- CAN 2.0B or TTL UART, selectable
- ROS 2 driver and open register map
Tooling
A hand you can change.
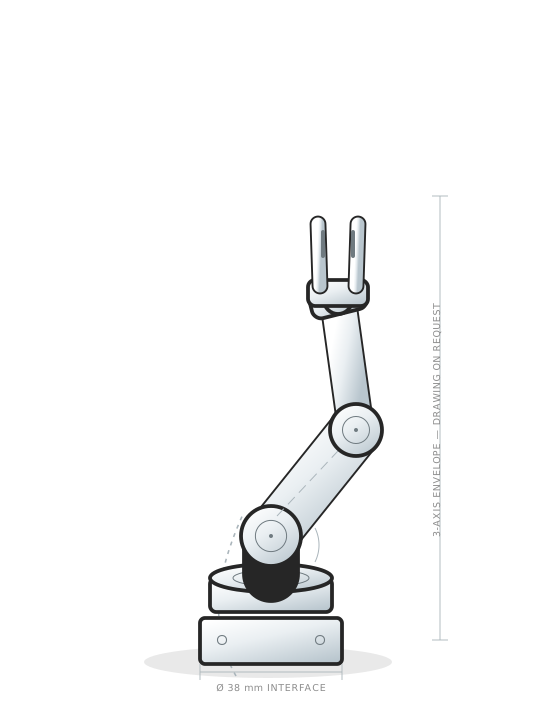
Every jaw and tool shares the same Ø 38 mm interface. Swap a parallel jaw for a soft jaw, a cutter or a camera mount without returning the arm or re-zeroing the vehicle.
- Standard, parallel and soft jaws
- Rope cutter, recovery basket, camera mount
- Tool change with the arm on the vehicle
Specifications
SubArm5 Lite, in full.
| Mechanical | |
|---|---|
| Axes | 5 — base yaw, shoulder, elbow, wrist pitch, wrist roll |
| End effector | Parallel jaw, interchangeable via Ø 38 mm interface |
| Mass | 800 g including gripper |
| Envelope | Ø 38 mm arm body |
| Mounting | Quick-release flange, 4 × M4 |
| Rotation | Continuous on base yaw and wrist roll |
| Electrical | |
| Input voltage | 10–32 V DC |
| Protocol | CAN 2.0B or TTL UART, selectable |
| Connector | Single sealed connector, power and comms |
| Actuation | All-electric, sealed joints — no hydraulics, no oil |
| Control | |
| Controller | SubArm Ctrl — gesture, touch, joystick, Joy-Con, SpaceMouse, keyboard |
| Host software | Windows / Linux |
| Interface | ROS 2 package, open protocol, spatial inverse kinematics |
Specifications are subject to change. The mounting drawing issued with every quote is the controlling document.
Tooling
One interface, six hands.


Questions
Before you integrate.
Does SubArm5 Lite need a hydraulic power unit?
No. Every joint is electric and sealed. The arm runs from 10–32 V DC and a CAN or TTL link, so there is no pump, reservoir, valve pack or oil to leak.
Can it run from the ROV’s existing 12 V or 24 V bus?
Yes. The input range covers both, with headroom for a 6S pack or a 32 V rail. Current draw depends on the move; the datasheet lists the figure for each joint.
How is the arm controlled?
With SubArm Ctrl for piloted intervention, or directly over ROS 2 for autonomy. Both use the same spatial inverse-kinematics layer, so Cartesian moves behave the same way.
Can I fit my own gripper or tool?
The Ø 38 mm interface is documented in the mounting drawing issued with every quote. Custom tools can be driven from the auxiliary tool channel.
What is in the box?
The arm with a standard parallel jaw fitted, a sealed cable set, the quick-release mounting flange and a quick-start card. Other jaws are ordered separately.
Next step
Put a hand on your ROV.
Send the vehicle, the voltage and the task. We will reply with the mounting drawing, the control notes and a quote.