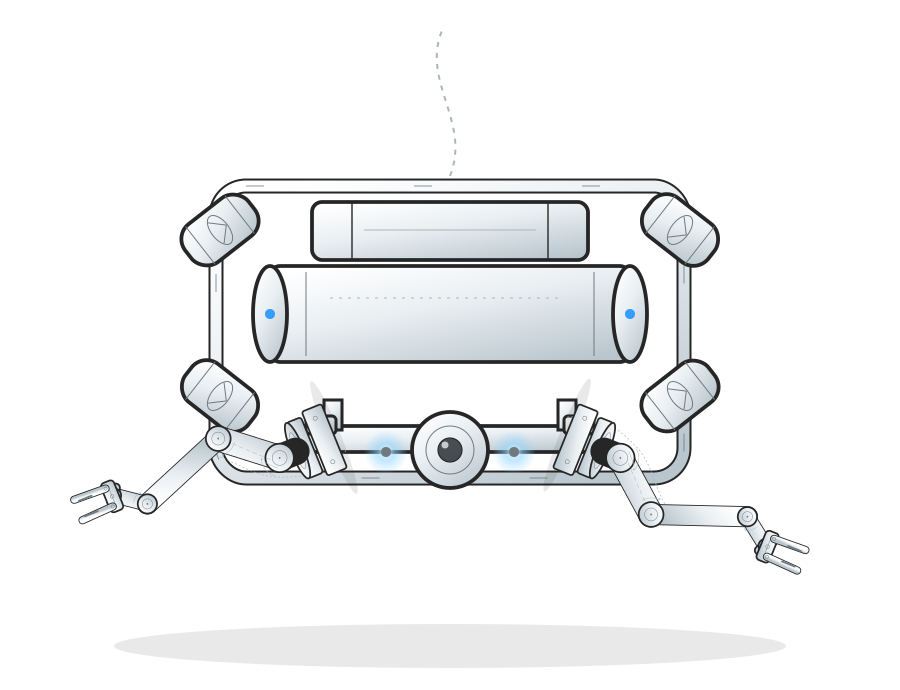
 Render
Dual-arm · 10 axes
SubArm5 Lite Duo
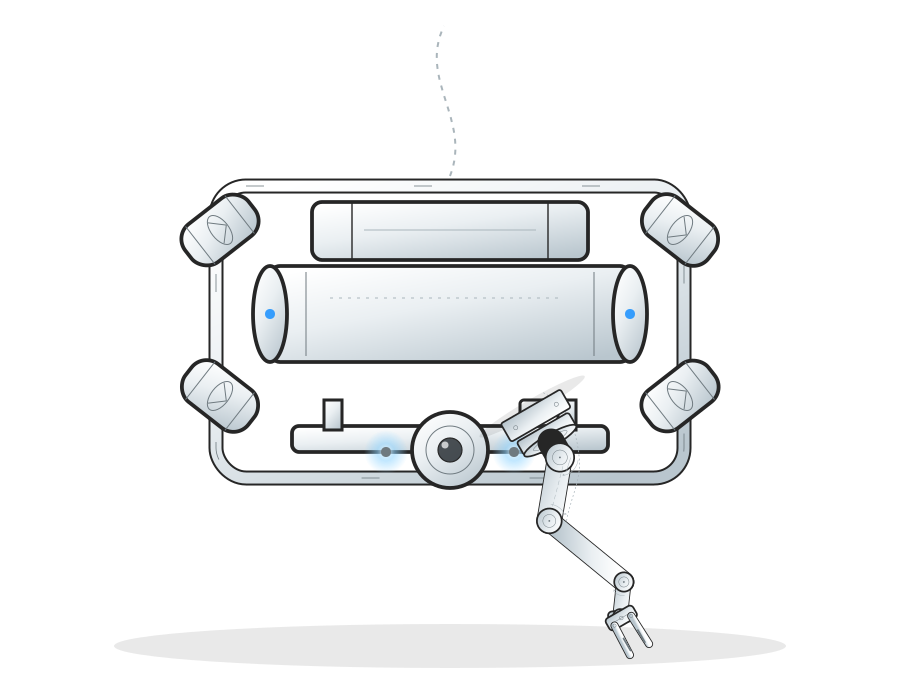
Two five-axis arms, one pilot, one interface. Dual-arm dexterous intervention for an inspection ROV.
- Two arms, one SubArm Ctrl
- One-to-two split interface
- 10–60 V wide-range input
- Axes
- 10 (2 × 5)
- Arms
- 2 × SubArm5 Lite
- Input
- 10–60 V DC
- Comms
- Dual CAN / TTL
- Interface
- One-to-two split
- Control
- SubArm Ctrl, both arms
The Duo is quoted as a system: two arms, the split interface, cable set, brackets and tool kit. Vehicle integration drawing supplied with the quote.
Dual-arm
Two hands change what a small ROV can do.
One arm can hold. Two arms can hold, cut and recover. SubArm5 Lite Duo mounts a pair of five-axis arms on the same vehicle and gives one pilot cooperative control of both — without a second ROV, tether or operator.
Cooperation
Two hands, one pilot.
Both arms are driven from one SubArm Ctrl. The pilot can hold a structure with one hand and work on it with the other, or run a combined Cartesian move that keeps the grippers in a fixed relationship.
- One pilot, two arms
- Independent or cooperative moves
- Shared emergency stop
Interface
One-to-two, by design.
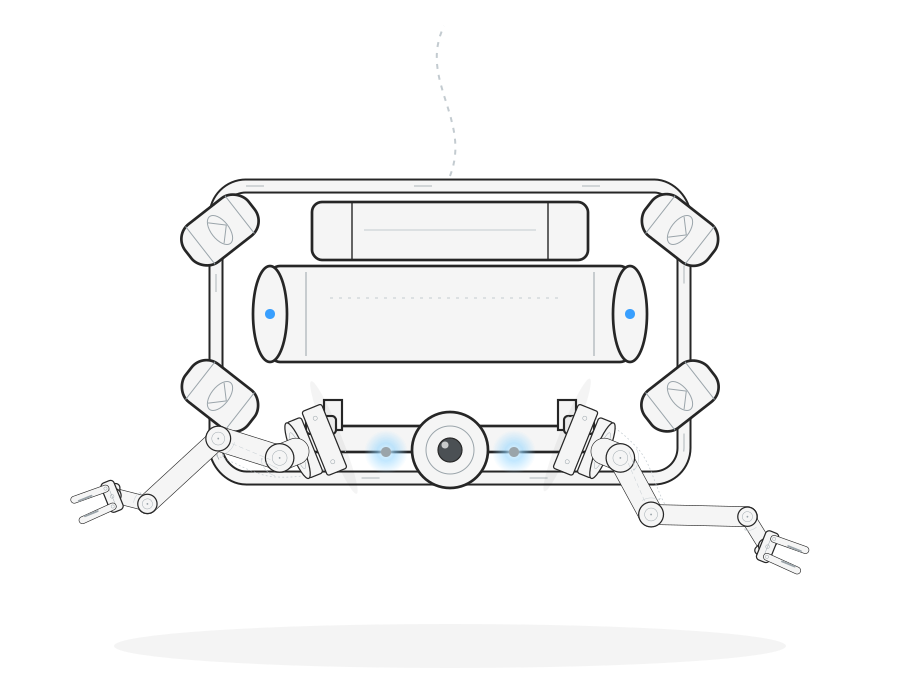
A single power and comms pair leaves the vehicle and splits at the tool skid. Both arms see the same 10–60 V rail and the same bus, so integration is one connection, not two.
- Single vehicle-side connector
- Split interface rated for both arms
- Dual CAN / TTL links
Power
10–60 V, no converter.
The wide input range covers 12 V, 24 V and 48 V vehicle rails with margin. No DC-DC converter on the skid, and no derating for a low battery.
- 12 / 24 / 48 V nominal rails
- No external converter
- Continuous rotation retained
Tooling
A toolkit, not a tool.
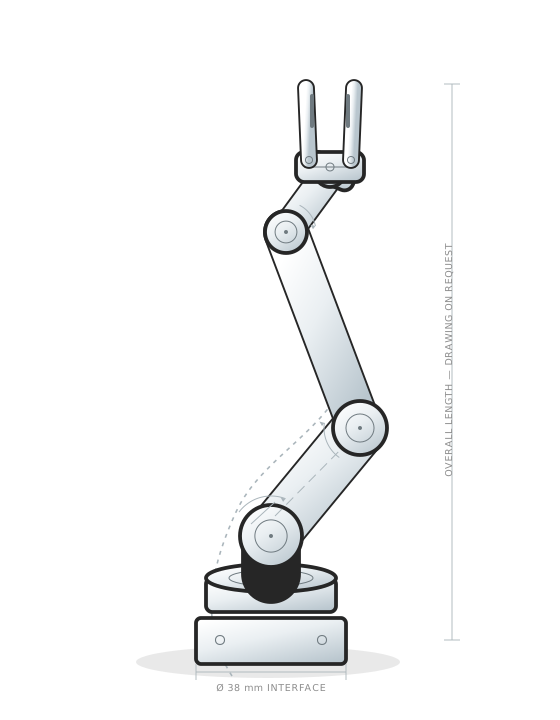
Each wrist takes any of the six SubArm tools. Common pairs are a standard jaw with a cutter, or a soft jaw with a recovery basket — hold with one hand, work with the other.
- Jaws, cutter, basket and camera mount
- Independent tool change per wrist
- Shipping bracket for transit
Specifications
SubArm5 Lite Duo, in full.
| Mechanical | |
|---|---|
| Configuration | Two SubArm5 Lite arms on a shared tool skid |
| Axes | 10 — five per arm |
| End effectors | Independent, Ø 38 mm interface per arm |
| Mass | Configuration dependent — request the drawing |
| Mounting | ROV tool skid or structural rails |
| Rotation | Continuous base yaw and wrist roll per arm |
| Electrical | |
| Input voltage | 10–60 V DC |
| Interface | One-to-two split, one vehicle-side connector |
| Protocol | Dual CAN 2.0B / TTL UART |
| Actuation | All-electric, sealed joints |
| Control | |
| Controller | One SubArm Ctrl for both arms |
| Host software | Windows / Linux |
| Interface | ROS 2, open protocol, cooperative Cartesian mode |
Specifications are subject to change. The mounting drawing issued with every quote is the controlling document.
Tooling
One interface, six hands.


Questions
Before you integrate.
Can one pilot really fly two arms?
Yes, with a mode that maps the hand controller to one arm at a time and a cooperative mode that moves both in a fixed relationship. The pilot switches with the controller, not the tether.
Does the Duo need a bigger ROV?
It needs two Ø 38 mm mounts and 10–60 V at the skid. Because the arms are 800 g each, the payload penalty is small compared with a hydraulic pair.
Are the arms independent if one fails?
Each arm has its own controller and bus link. A fault is isolated to one arm, and the vehicle can recover with the other.
What is included in the Duo system?
Two arms, two jaws of your choice, the split interface, the cable set, mounting brackets, a transit brace and the ROS 2 package.
Next step
Give the ROV two hands.
Send the vehicle layout and the task. We will size the split interface, the brackets and the tool pair.